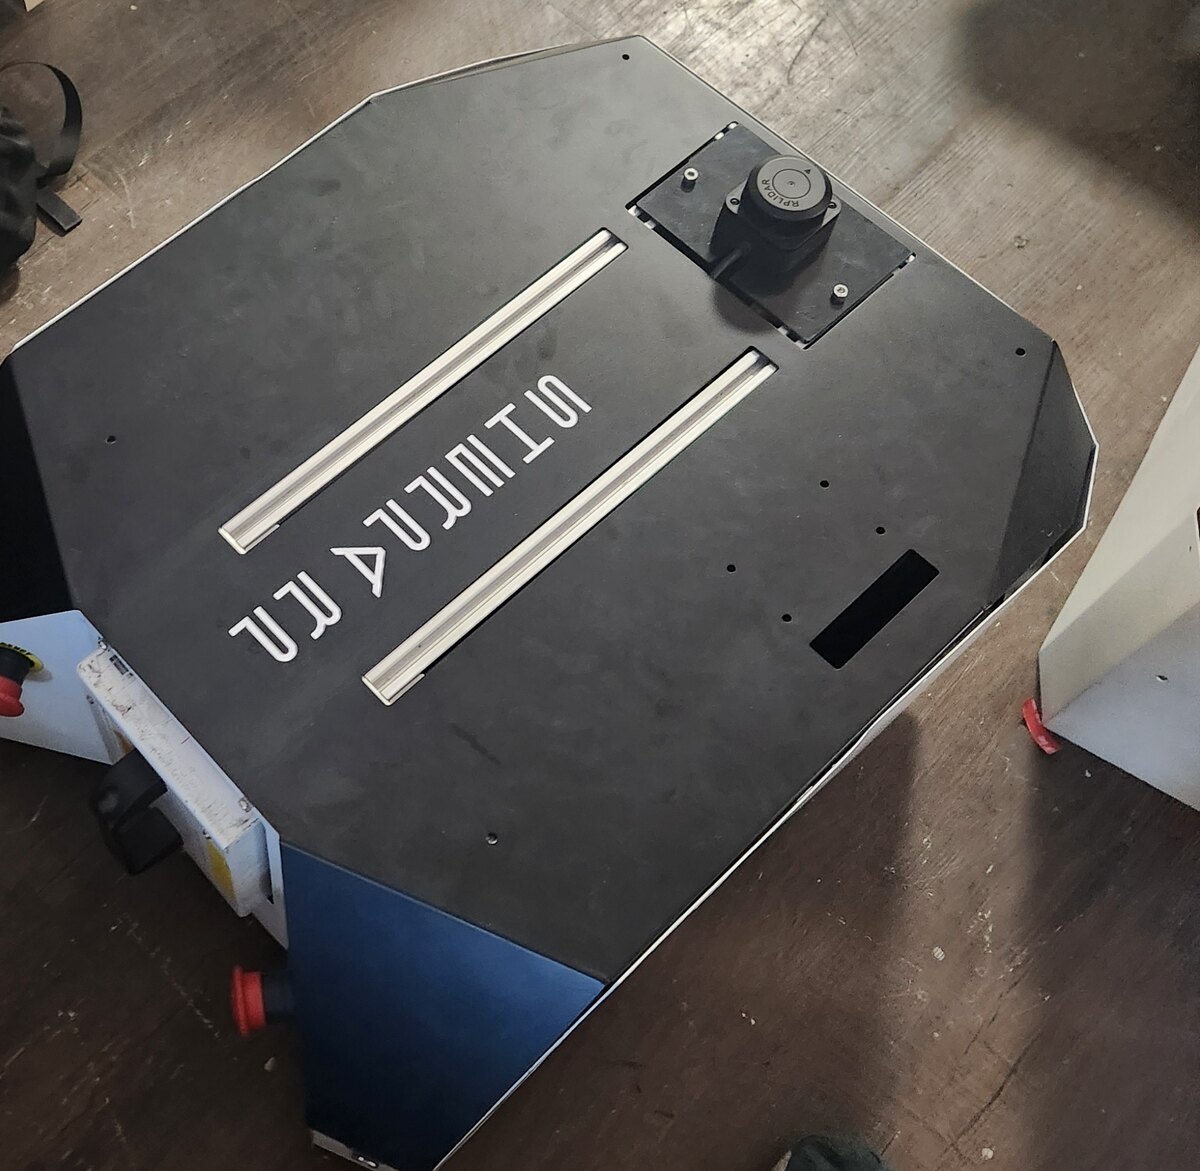
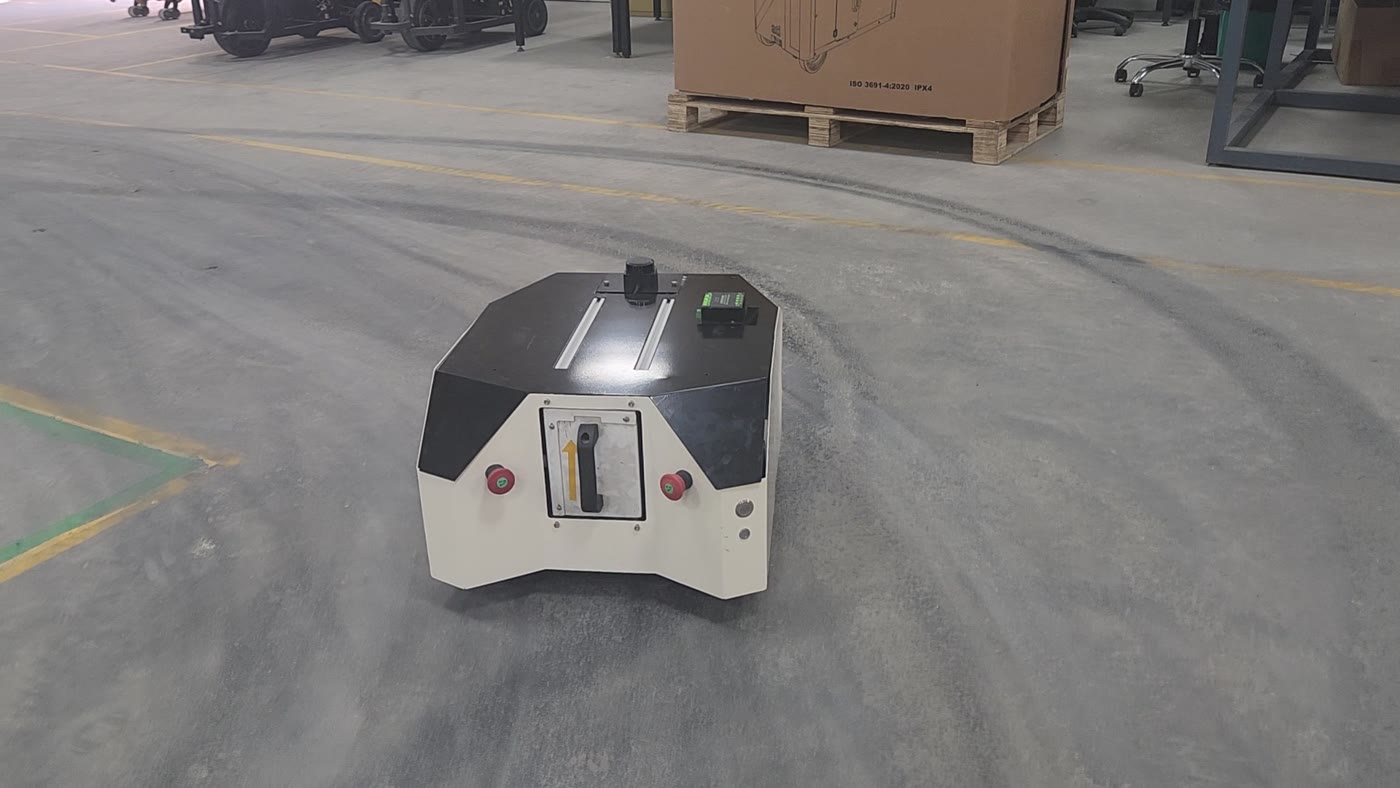
Ati Motors — autonomous mobile robot

What it is
A light-duty autonomous mobile robot for education and warehousing, developed at Ati Motors in Bengaluru. I led its development as a new product initiatives intern, between September 2024 and April 2025. Three units were built: one kept internally, one delivered to Christ College Bengaluru and one to VIT Coimbatore, both to serve as ROS 2 mules for their robotics programmes.
The problem and the constraint
Ati’s other robots are built to move payloads on a factory floor. This one had a different job. A university robotics programme needs a platform that students can put their own code on and drive around a corridor — which means the autonomy has to be complete enough to work out of the box and open enough that somebody can replace a piece of it without the robot becoming inert.
The other constraint was that I was an intern with an end date. Anything I built that only I understood would stop working the moment I left.
What I did
I wrote the autonomy codebase in ROS 2 and brought it up across all three units. Then I deployed and maintained two of them in the field, which meant the whole lifecycle rather than the interesting part of it — commissioning on a site I did not design, mapping a building somebody else uses, and after-sales support when something stopped working on a Tuesday.
Field support is where the actual learning is. A robot that navigates a corridor reliably in the lab will find a way to fail in a building with glass doors, a floor that reflects, and people who move furniture. Every one of those is a bug you cannot reproduce at your desk.
Before I finished, I trained my successor and wrote up the technical workflows — the bring-up sequence, the deployment steps, the things that are not obvious from the code. Handing a project over properly is the part of an internship that is easiest to skip and hardest to justify skipping.
Gallery